Workshop robot: rigid hard-surface rig
An original chunky workshop robot with a screen face: hard parts rigged rigidly, a rubber bellows and a spring antenna for life.
- Triangles
- 7,828
- Bones
- 37 (32 deform)
- Rigid vertices
- 3,874 of 4,214 on one bone
- Clip
- Stomp walk, look-around, wave
-
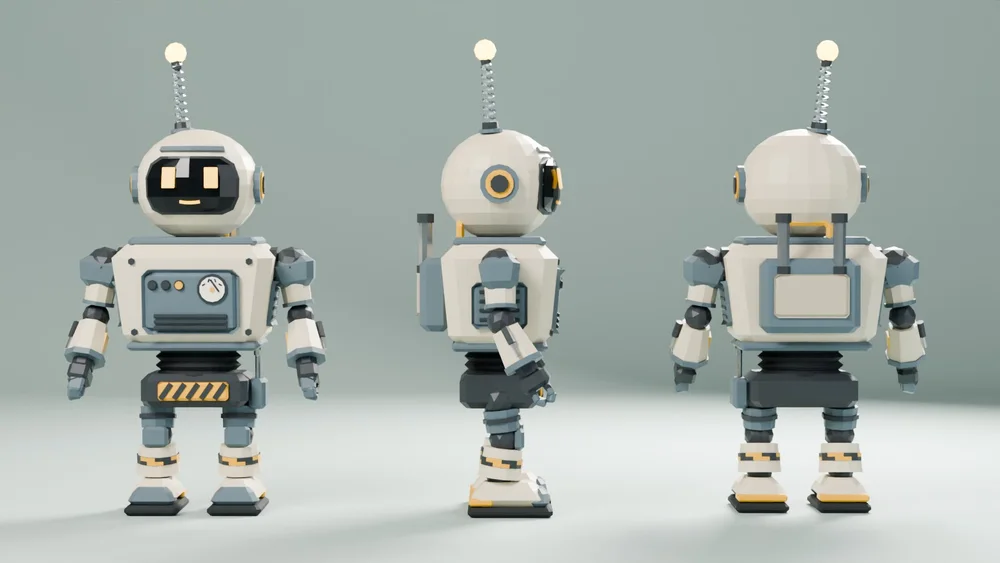
Front, side and back: boxy torso with gauge and vents, piston arms with claws, backpack exhausts.
-
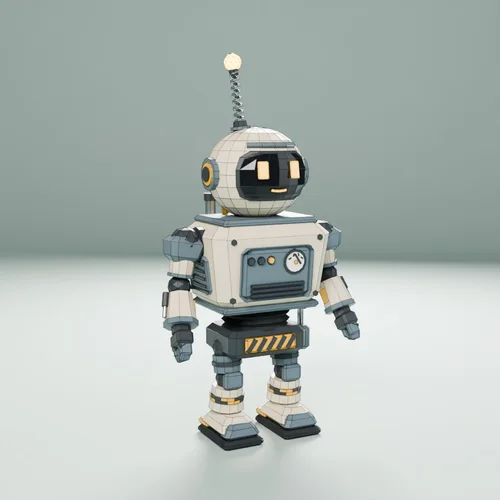
Hard-surface low poly: bevelled panels, separate mechanical parts.
-
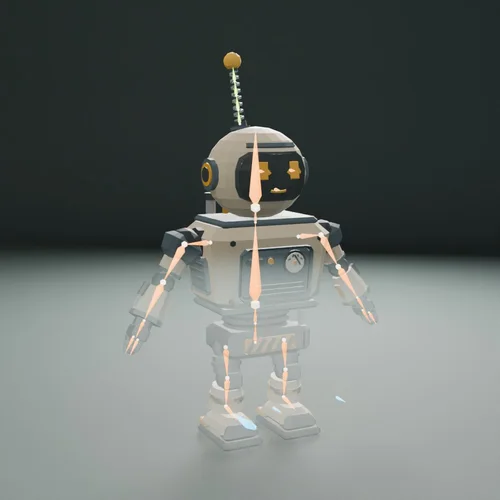
Skeleton: rigid per-part bones, IK legs, claw jaws, a 4-bone spring antenna, screen-face bones.
-
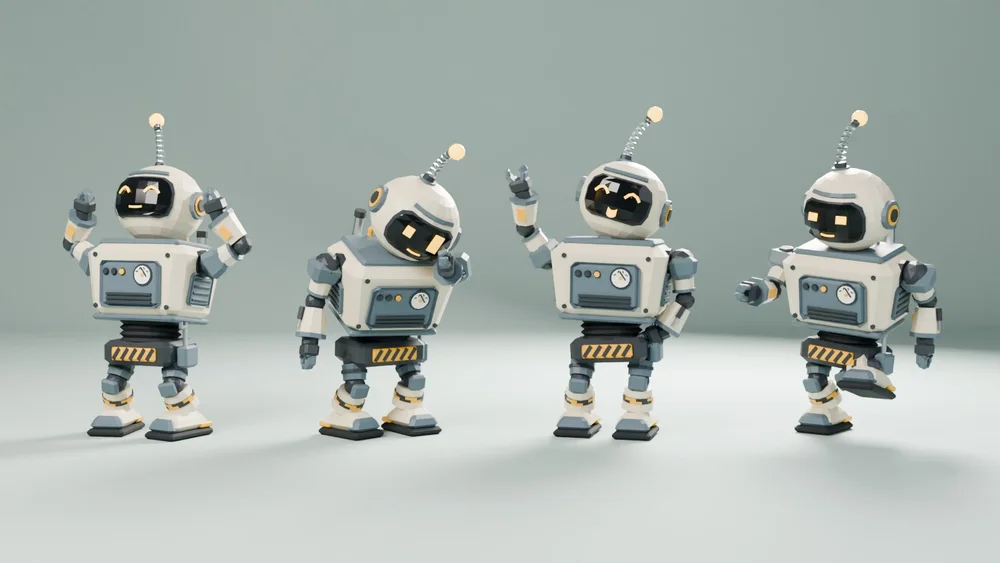
Poses: heavy step, look-around with the antenna whipping, claw wave, happy eyes.
What it shows: mechanical rigging. Each hard part follows exactly one bone, so nothing bends that should not; only the rubber waist and the antenna coil deform. The stomp has weight: the body drops and rebounds on each step.
Own demo: an original character designed, modelled, rigged and animated by me in Blender for this portfolio. Delivered as .blend and FBX for Unity or Unreal.